
Embodied Robotics
Solutions
Overview
Independently developed by JIIOV, Embodied Robotics Solutions is a comprehensive solution for robotic perception and interaction, designed to address two core challenges in the development of embodied intelligence: the lack of high-performance tactile sensing capability, and the scarcity of high-quality, scalable tactile datasets. The system integrates three core modules—a spatial data processing platform, egocentric data collection devices, and visuo-tactile interaction solution—providing end-to-end support for the training, refinement, and deployment of dexterous manipulation skills.
Key Advantages
Spatial Data Processing Platform
Built on JIIOV's proprietary computing power management platform and model development toolchain, this platform provides large-scale multimodal data processing and management for embodied AI. It supports automatic data parsing, temporal alignment, quality assessment, screening and cleaning, structured annotation, and unified management. It also supports the reconstruction and generation of key information such as spatial positioning, environmental perception, hand interaction trajectories, and action events, improving both the efficiency and the standardization of turning raw data into training data. This gives embodied AI model training, evaluation, and iteration a stable data infrastructure. In its core focus area of hand interaction, JIIOV has world-class algorithms and technical capabilities, and won the HANDS International Challenge in 2023, 2024, and 2026.
Learn More About Hand-tracking Solutions
Egocentric Data Acquisition and Video Processing Demo: Medication Sorting and PackagingEgocentric Data Acquisition and Video Processing Demo: Cup Separation
Egocentric Data Collection Devices
A lightweight wearable data capture device self-developed by JIIOV, integrating egocentric visual capture, head pose sensing, hand motion capture, eye tracking, ambient light sensing, and spatial positioning capability. This type of device can continuously and reliably capture high-quality multimodal raw data of human interaction in real-world environments. To date, it has accumulated over 30,000 hours of structured egocentric perceptual data, which can be used to support the training and continuous iteration of embodied intelligence models.
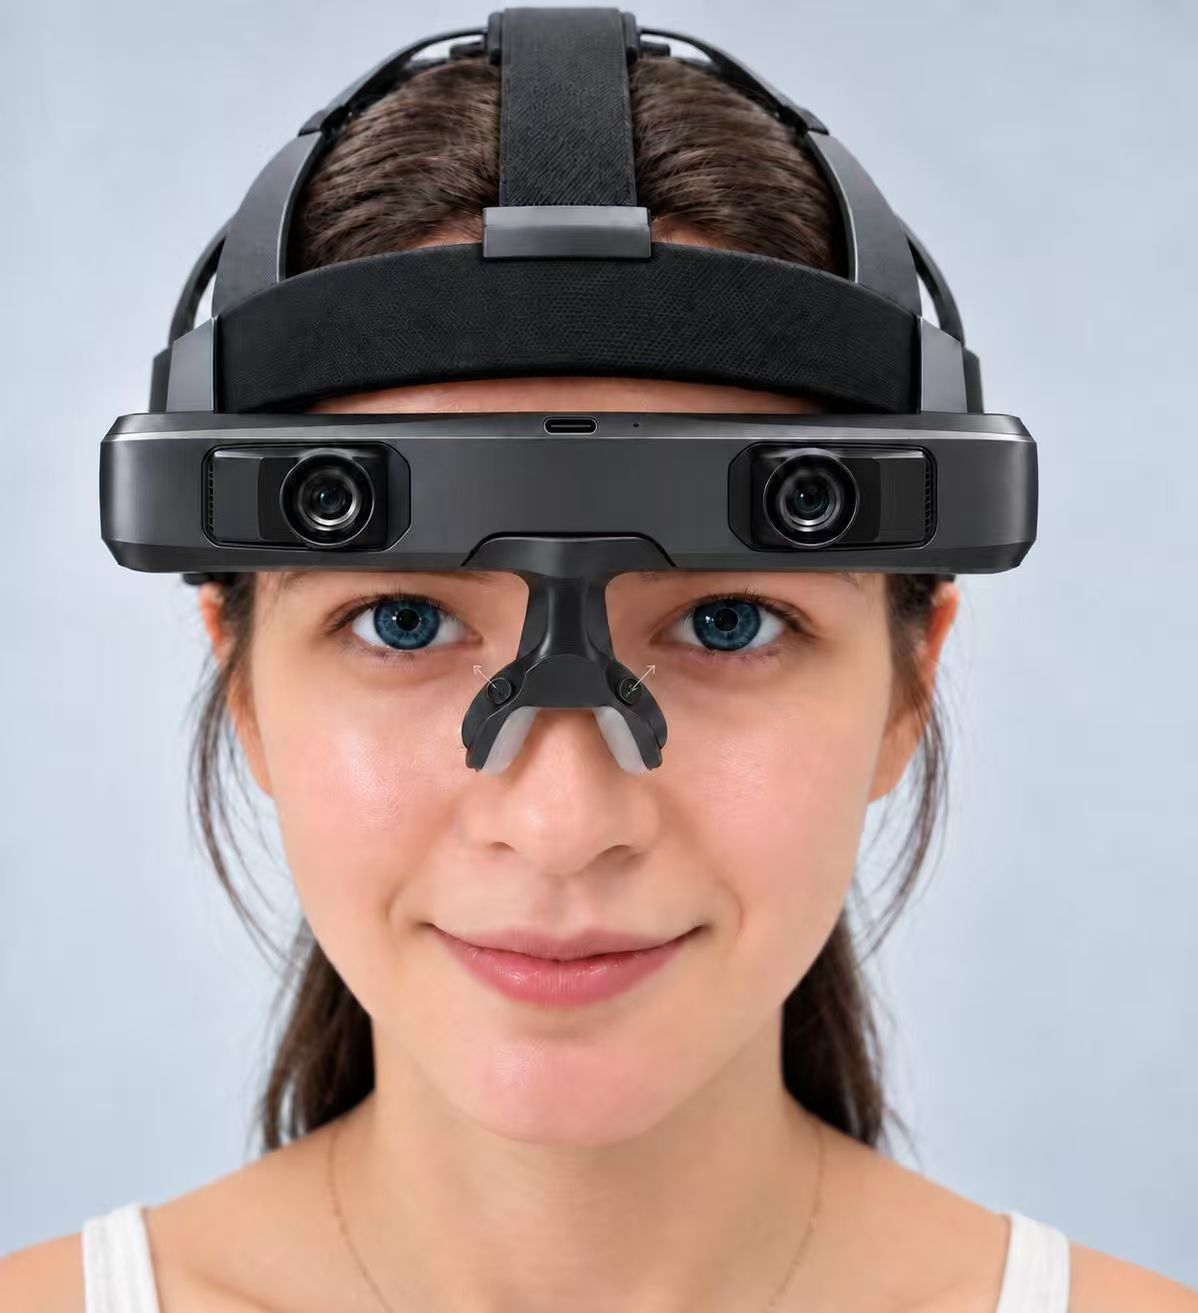
Product images are for reference only. Actual products may vary.
Visuo-tactile Interaction Solution
JIIOV provides a cross-modal visuo-tactile interaction solution for dexterous hands and other embodied intelligence applications, fusing visual perception with tactile feedback to enable coordinated sensing of object contact state, surface texture, force variation, and the manipulation process. This allows devices to more accurately understand object properties and interaction states, significantly improving fine manipulation, stable grasping, and complex task execution capability. Among its offerings, the 5mm ultra-thin solution supports wearable data capture and enables alignment between human manipulation data and robotic dexterous-hand data.
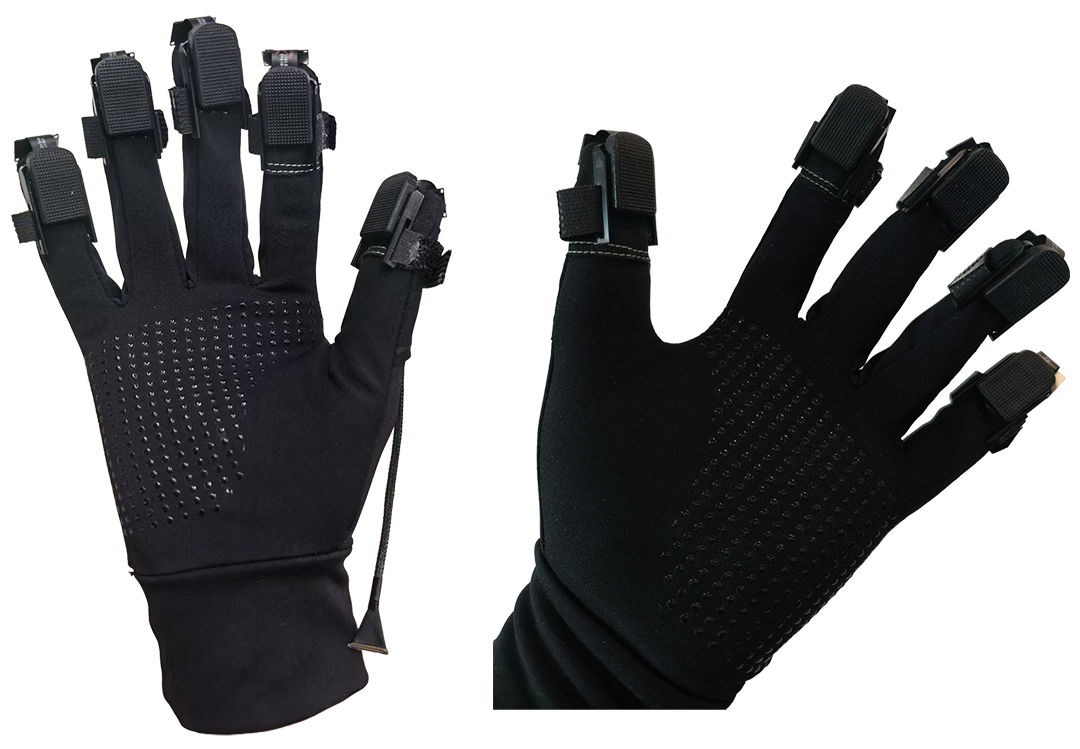
Product images are for reference only. Actual products may vary.
Ultra-Thin Visuo-tactile Module JVR507-AA5A
Technical Specifications
| Specification | JVR507-AA5A |
|---|---|
| Module Size (X * Y * Z) | 22.9x16.0x5.0mm |
| Weight | 2g |
| Thickness | 5.0mm |
| Sensing Area | 94mm² |
| Sampling Frequency | 30~50(FPS/Hz) |
| Camera Resolution | (148x148)x4 |
| Sensing Resolution | 262x288 |
| DPI | 525 |
| IMU | ±2g/±4g/±8g/±16g |
| Temperature Sensor | -40°C to 125°C |
| Working Power Consumption | 245mW |
| Stand-by Power Consumption | 105mW |
| Interface | SPI |
Key Features and Advantages
- High-precision tactile sensing
- System-level synchronization: the main controller synchronizes tactile data, IMU, and temperature sensor readings, simultaneously capturing tactile, pose, and temperature information
- Built on a validated supply chain, ready for mass production
- Adaptable to a wide range of deployment scenarios and data-collection needs
